

Product information
Overview
Key Features
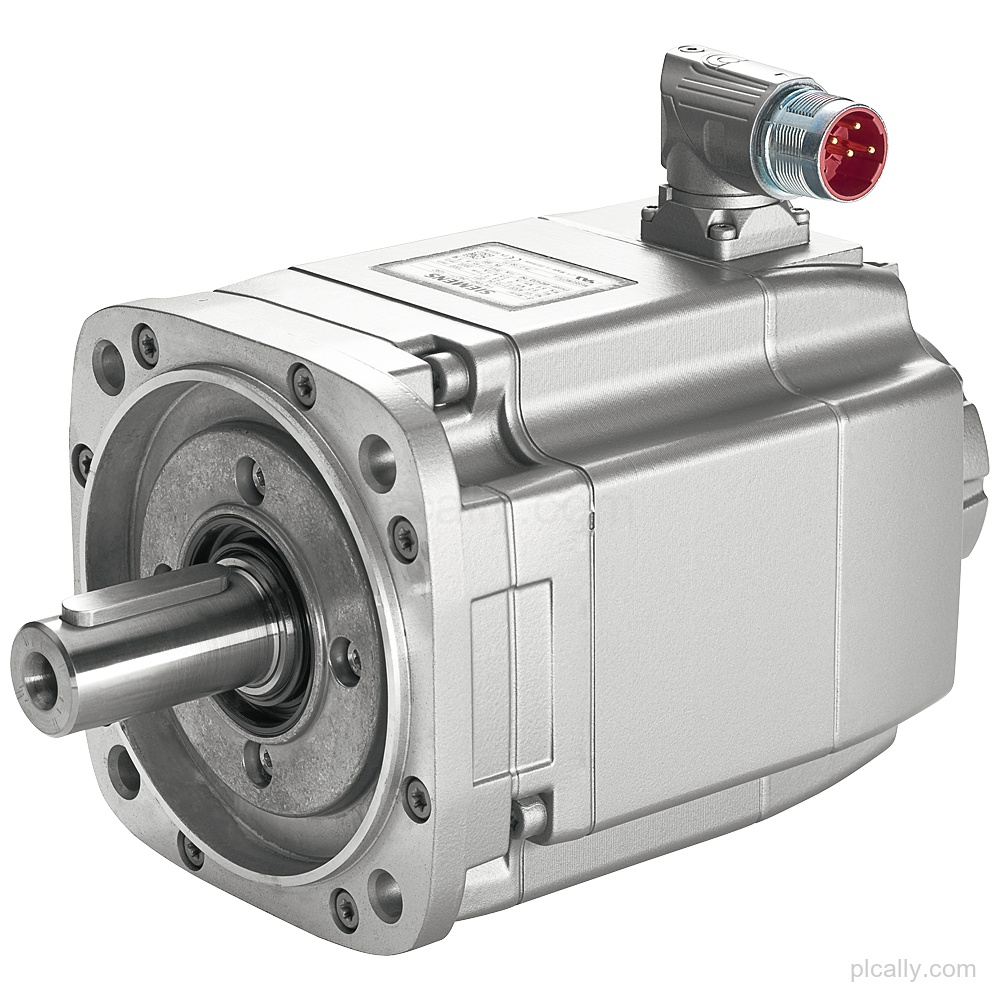
- Motor performance: Optimum power: 1.2 kW; optimum speed: 4,500 rpm; rated torque: 2.6 Nm (100 K).
- Absolute encoder feedback: Encoder AM22DQ: absolute encoder 22 bits (resolution 4194304, encoder-internal 2048 S/R) + 12 bits multi-turn (traversing range 4096 revolutions).
- Electrical limits: UDC: 600 V; rated current: 3.3 A; maximum current: 12.5 A; maximum torque: 10.0 Nm.
- Mounting and connections: Design acc. to Code I: IM B5 (IM V1, IM V3); M23 connector size; signals and power connectors are rotatable.
- Holding brake: Permanent-magnet brake with 4.0 Nm holding torque and DC 24 V ± 10 % power supply voltage.
- Cooling and protection: Natural cooling and IP65 degree of protection.
Technical Summary
| Product type | Permanent-magnet synchronous motor |
|---|---|
| Optimum power | 1.2 kW |
| Optimum speed | 4,500 rpm |
| Rated torque | 2.6 Nm (100 K) |
| DC link voltage | 600 V |
| Maximum torque | 10.0 Nm |
| Encoder | AM22DQ absolute Encoder, 22 bits + 12 bits multi-turn, with DRIVE-CLiQ interface |
| Mounting design | IM B5 (IM V1, IM V3) |
| Connector size | M23 |
| Holding brake | Permanent-magnet brake, 4.0 Nm holding torque |
| Cooling | Natural cooling |
| Degree of protection | IP65 |
Frequently Asked Questions
What feedback system does the 1FK7043-4CH71-1FB1 use?
It has an absolute Encoder AM22DQ with 22 bits, resolution 4194304, encoder-internal 2048 S/R, and 12 bits multi-turn with a traversing range of 4096 revolutions. The interface is DRIVE-CLiQ.
What are the motor's power and speed values?
Optimum power is 1.2 kW and optimum speed is 4,500 rpm. Rated torque is 2.6 Nm (100 K), and maximum torque is 10.0 Nm.
Which mounting and connector configuration does it have?
The design is IM B5 (IM V1, IM V3). It has an M23 connector size, with rotatable connectors for signals and power.
What quantity, destination and requested date should be included for a quotation?
Send the required quantity, destination and requested date for model-specific quotation support.